Buy in Germany
checked 2026-11-06Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
Not on sale yet: XPENG targets mass production by the end of 2026, market launch and deliveries in 2027 and a European rollout in H2 2027, but names no price, countries or sales route, and no order is open. Lead time: European rollout targeted for H2 2027 (maker timetable, October 2026); a target, not an order date..
Checked 2026-11-06. Maker’s page ↗
Key facts
All specifications- Moves on
Legs
- Height
- Weight
- Arms
2
- Hands
Multi-finger hands
- Payload per arm
20 kg
Arm or total not stated; Listed as "Strength" by humanoid.guide; measurement basis not stated.
Reported · humanoid.guide ↗- Carry on body
- Not published
- Runtime
- Max speed
1.94 m/s
Reported · humanoid.guide ↗- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Price and delivery outside Germany1 reported by databases, not by a sellerShowHide
Price and delivery
0 seller prices · 1 reported| Region | Config | Price | Evidence |
|---|---|---|---|
| GLOBAL | base reported estimatehumanoid.guide · 12 Sept 2026 | US$150,000 | reported estimatehumanoid.guide · 12 Sept 2026 |
- GLOBALReported: Not sold yetNot sold yetrobotpriceindex.com · 12 Sept 2026
Jobs
Needs add-ons or a trial 11
- Check components before assembly handoffFactory parts-preparation trial
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Kit fittings and hardware for element assemblyPrefab timber house factory
- Pick automotive components from flow racksAutomotive parts-sorting station
- Record humanoid manipulation demonstrationsHumanoid learning and teleoperation laboratory
Show 6 more
- Research picking objects from floor levelControlled laboratory floor and tabletop
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
- Restock fastener magazines, clear packaging, tidy workstationsPrefab timber house factory
- Sequence automotive parts into delivery trolleysAutomotive assembly logistics
- Study fingertip contact during humanoid graspsDexterous manipulation research cell
- Test learned manipulation policies on a physical humanoidRobot learning evaluation cell
Where it has worked
- Made for this work
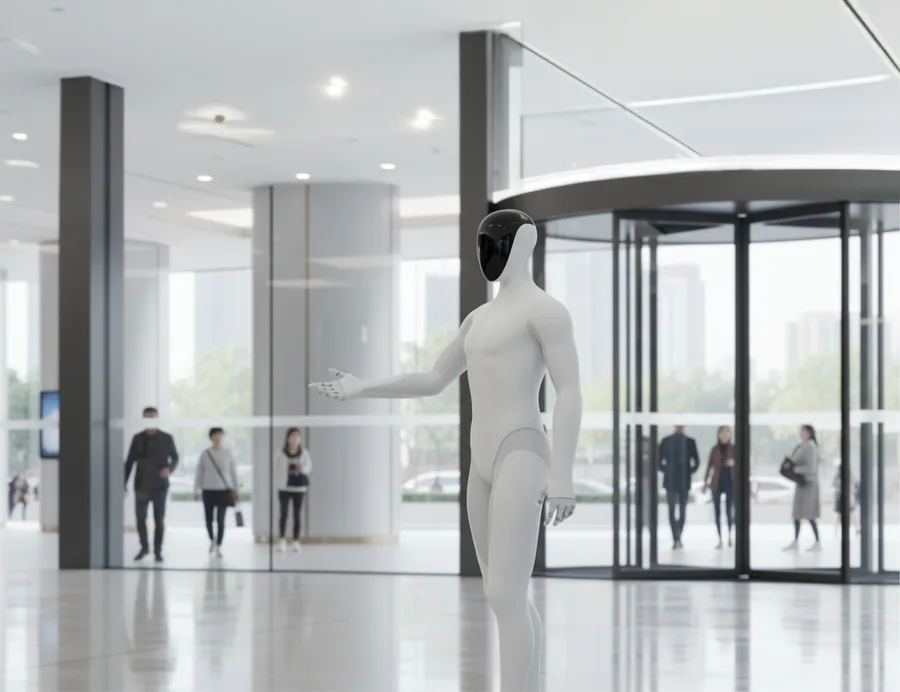
Tour guide, shopping guide and patrol guide in commercial settings
XPENG ↗
Specifications
12 catalogue values · 0 verifiedSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
XPENG IRON5 specifications · 8 research gaps · reviewed Show all 5 specifications and capabilities
- DOF per hand
XPENG releases of August and September 2026; the product page still says 22
- Shoulder (scapula) DOF
- Battery
- Compute
effective computing power, maker figure
- Dof total
whole body, as stated by XPENG in September 2026
Capabilities and equipment
- Legs
- YesField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Unknown
- Outdoor use
- Unknown
- Number of arms
- 2Field-level source not recorded
- Hands or end effectors
- Dexterous handsField-level source not recorded
- Hands included
- YesField-level source not recorded
- Payload per arm
- Unknown
- Payload on body or base
- Not applicable
- Runtime
- Unknown
- IP rating
- Unknown
- SDK / development interface
- Unknown
Operating conditions and configuration notes
- No payload, runtime or size published.
Still missing for XPENG IRON
Payload per arm · Payload, both arms · Runtime · IP rating · Stairs · Rough ground · Outdoor use · SDK / development interface
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- XPENG Next-Gen IRON ↗Manufacturer source · checked
Catalogue specifications
Catalogue values for the base record.
| Size and weight | |||
|---|---|---|---|
| Height | 1.78 m | Reported | robotpriceindex.com |
| Weight | 70 kg | Reported | robotpriceindex.com |
| Payload | |||
| Payload | 20 kg Listed as "Strength" by humanoid.guide; measurement basis not stated. | Reported | humanoid.guide |
| Mobility | |||
| Walking speed | 1.11 m/s | Reported | humanoid.guide |
| Max speed | 1.94 m/s | Reported | humanoid.guide |
| Power | |||
| Runtime · basis unstated | 4 h | Reported | humanoid.guide |
| Kinematics | |||
| Degrees of freedom | 62 | Reported | robotpriceindex.com |
| DOF hands | 21 | Reported | robothub.app |
| Commercial | |||
| Availability | Prototype | Reported | humanoid.guide |
Not published · 17
Not published anywhere we could find. | |||
Sources disagree
- Weight
- Degrees of freedom
- Max speed
- 1.9444humanoid.guide
- 1.3889humanoid.guide
- Runtime · basis unstated
- Compute
- 3 XPeng Turing AI chips; physical-world foundation model; 2250 TOPS effective computerobothub.app
- XPENG Turing AI chipshumanoid.guide
- Availability
- Prototypehumanoid.guide
- Contact for availabilityhumanoidhub.ai
More detail
Parts, equipment and evidence profileShowHide
Built-in parts
what ships insideFingers
Reportedhumanoid.guide· 12 Sept 202610
Compute
Reportedrobothub.app· 12 Sept 20263 XPeng Turing AI chips; physical-world foundation model; 2250 TOPS effective compute
Connectivity
Reportedhumanoid.guide· 12 Sept 2026Cloud‑connected
Not published: Hands, LiDAR, Cameras, Equipment options.
Robot evidence profile
2 of 10 axes with data · tasks UnknownProfile scope: Catalogue model. The chart uses this catalogue record. Configuration-specific findings are listed separately below.
Chart gaps mean evidence is missing. Scores describe the published data against fixed thresholds; they do not predict task success.
Carryunconfirmedworking payload not confirmed; preferred source gives only a peak or unqualified load1 recorded field · 1 follow-up
Rated payload against 5, 10, 20, 40 and 80 kg.
Payload: 20 kg
Listed as "Strength" by humanoid.guide; measurement basis not stated.
Still needed
- Rated working load, arm pose and whether the figure is per arm or combined
Ask before use: What load can this exact configuration sustain while doing the intended task?
Reachunconfirmedworking reach not published; body height does not establish tool or handling reach0 recorded fields · 1 follow-up
Work height against 1.0, 1.5, 2.0 and 2.5 m; unknown when working reach is not published.
No supporting catalogue specification is recorded for this axis.
Still needed
- Vertical working reach from the floor, including the end effector
Ask before use: What usable tool height and work envelope are supported by the fitted arm and base?
Stairs & slopeunconfirmedstair capability not published0 recorded fields · 3 follow-ups
Stair capability, and slope against 10, 20, 30 and 45°.
No supporting catalogue specification is recorded for this axis.
Still needed
- Explicit stair-climbing capability
- Maximum step height and test conditions
- Maximum slope and test surface
Ask before use: Which stair geometry, surface and carried load were tested?
Terrainunconfirmedgravel capability needs configuration-specific evidence0 recorded fields · 2 follow-ups
Configuration-specific evidence for gravel and rubble.
No supporting catalogue specification is recorded for this axis.
Still needed
- Named terrain and configuration-specific test evidence
- Reviewed evidence for gravel and rubble separately
Ask before use: Is gravel or rubble explicitly supported for this configuration? General uneven-ground claims do not establish both.
WeatherunconfirmedIP rating not published0 recorded fields · 3 follow-ups
Heavy dust, damp and rain (IP code), outdoor rating, and −10…35 °C / −20…45 °C.
No supporting catalogue specification is recorded for this axis.
Still needed
- Whole-robot IP rating
- Explicit outdoor-use permission or restriction
- Complete operating temperature range
Ask before use: Do weather ratings apply to the whole robot, including its hands, sensors and battery?
Enduranceunconfirmed4 h (basis unstated) published; loaded work runtime not confirmed1 recorded field · 1 follow-up
Published loaded runtime against 2, 4 and 8 h shifts; nominal/idle figures remain unconfirmed.
Runtime · basis unstated: 4 h
Still needed
- Loaded working runtime with workload stated
Ask before use: How long does it operate with the intended payload and duty cycle, including recharge or battery changes?
Autonomyunconfirmedlevel of autonomy not assessed0 recorded fields · 1 follow-up
Supervised, then fully autonomous operation.
No supporting catalogue specification is recorded for this axis.
Still needed
- Operator role and supported autonomous workflow
Ask before use: Which tasks run without teleoperation, and when must a person intervene?
Handling evidence0/6 supported0 supported; 0 reported only; 6 unconfirmed. Counts describe evidence, not task success.0 recorded fields · 1 follow-up
Supported, reported and unconfirmed handling tasks. Incomplete evidence leaves a chart gap, not a success score.
No supporting catalogue specification is recorded for this axis.
Still needed
- Evidence for the required handling task and fitted end effector
Ask before use: Which grasp, tool and handling tasks have been shown with this exact end effector?
Evidence23/10012 populated fields, 0 manufacturer-sourced0 recorded fields · 0 follow-ups
How much of the record is published and maker-verified.
0 manufacturer-sourced · 0 assessed · 12 reported · 0 with confidence unconfirmed. 3 distinct source links.
Ask before use: Which claims have primary sources, and which still need manufacturer confirmation or a task trial?
A named task is a sourced capability claim. A task not listed remains unconfirmed.
No field-level task evidence is recorded. Task, configuration, source and operating conditions are needed.
Transport
- Carry materialnot assessed
- Fetch and delivernot assessed
- Pick from shelvesnot assessed
- Hand over toolsnot assessed
Inspection & capture
- Site inspectionnot assessed
- 360° progress capturenot assessed
- LiDAR scanningnot assessed
- Patrol / monitoringnot assessed
Manipulation & tools
- Teleoperated handlingnot assessed
- Drillingnot assessed
- Screwingnot assessed
- Sorting materialnot assessed
- Kittingnot assessed
- Machine tendingnot assessed
- Palletisingnot assessed
Navigation
- Navigate indoors alonenot assessed
- Navigate outdoors alonenot assessed
- Climb stairsnot assessed
Site work
- Layout markingnot assessed
- Sweepingnot assessed
- Surface finishingnot assessed
Evidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
XPENG IRON1 published claim · 7 missing capability fields
- Published claim
Tour guide, shopping guide and patrol guide in commercial settings
Location not recorded · Event date not recorded
XPENG ↗ · Manufacturer source · checked
What is still missing
Payload per arm · Payload, both arms · Runtime · IP rating · Stairs · Rough ground · Outdoor use
Unweighted thresholds use the matcher's rules. Handling shows evidence coverage. Source labels describe provenance and do not certify performance.
Sources
8 pages- XPENG Next-Gen IRON ↗XPENG · manufacturer · checked 2026-11-06
- Humanoids Daily ↗Humanoids Daily · press · checked 2026-11-06
- XPENG ↗XPENG · manufacturer · checked 2026-11-06
- https://humanoid.guide/product/iron/database · 14 values · seen 12 Sept 2026
- https://humanoid.guide/product/iron_prototype/database · 10 values · seen 12 Sept 2026
- https://robotpriceindex.com/robots/xpeng-irondatabase · 5 values · seen 12 Sept 2026
- https://www.humanoidhub.ai/robots/iron-humanoiddatabase · 4 values · seen 08 Sept 2026
- https://www.robothub.app/en/robots/irondatabase · 5 values · seen 12 Sept 2026
- Specification data cross-checked against the Humanoid Guide database (humanoid.guide).
- Price ranges cross-checked against Robot Price Index (robotpriceindex.com).
- Sensor and compute details cross-checked against HumanoidHub (humanoidhub.ai).
- Specification data cross-checked against RobotHub (robothub.app).