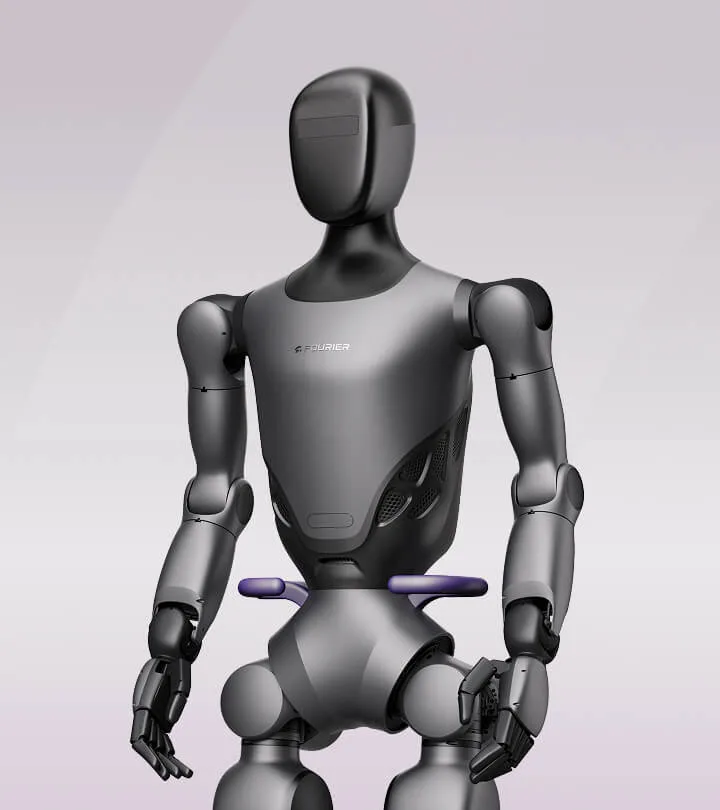
Buy in Germany
checked 2026-11-06Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
RBTX (igus, Cologne) lists GR-2 with a net price and a usual delivery time of 3 weeks. Lead time: 3 weeks (RBTX).
RBTX marketplace (igus SE & Co. KG) DE · reseller · €170,236 net
Checked 2026-11-06. Maker’s page ↗
Key facts
All specifications- Moves on
Legs
- Height
1.75 m
Maker · fftai.com ↗- Weight
- Arms
2
- Hands
Multi-finger hands
- Payload per arm
- Carry on body
- Not published
- Runtime
- Max speed
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Price and delivery outside Germany1 reported by databases, not by a sellerShowHide
Price and delivery
0 seller prices · 1 reported| Region | Config | Price | Evidence |
|---|---|---|---|
| GLOBAL | base reported estimaterobotpriceindex.com · 12 Sept 2026 | US$125,000 | reported estimaterobotpriceindex.com · 12 Sept 2026 |
- GLOBALReported: Enterprise onlyEnterprise onlyrobotpriceindex.com · 12 Sept 2026
Jobs
Made for this work 1
- Record humanoid manipulation demonstrationsMade for this work
Did similar work 1
- Test learned manipulation policies on a physical humanoidDid similar work · Whole-body VR teleoperation to record manipulation data
Specs fit 8
- Check components before assembly handoffFactory parts-preparation trial
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Kit fittings and hardware for element assemblyPrefab timber house factory
- Load sheet-metal parts into welding fixturesAutomotive body shop
- Pick automotive components from flow racksAutomotive parts-sorting station
Show 3 more
- Research picking objects from floor levelControlled laboratory floor and tabletop
- Return empty totes after pickingWarehouse empty-container return
- Study fingertip contact during humanoid graspsDexterous manipulation research cell
Needs add-ons or a trial 19
- Connect sprinklers to the branch lines with flexible hoses in suspended ceilingsSprinklers and extinguishing systems
- Fit lever handles to interior doorsJoinery, interior doors and hardware
- Insert insulation batts into the frame baysPrefab timber house factory
- Install presence detectors in suspended ceilingsBuilding automation
- Install sprinklers and set them to the ceilingSprinklers and extinguishing systems
Show 14 more
- Lay carpet tiles on tackifierFloor coverings and parquet
- Lay click parquet planks floating on an underlayFloor coverings and parquet
- Lay click vinyl planks floatingFloor coverings and parquet
- Lay drainage pipes inside the building to fallsWater, gas and drainage installations
- Lay impact-sound insulation and edge strips under a floating screedScreed
- Mount, connect and address room temperature controllersBuilding automation
- Preset thermostatic radiator valves for hydraulic balancingHeating installations
- Recover beverage cartons from paper linesMaterial recovery facility
- Recover light recyclables from residue beltsMaterial recovery facility
- Set corner beads before plasteringPlaster and stucco
- Tape the airtight window connections in prefabricated facade elementsFacade element prefabrication
- Test returned portable electrical tools before the next hireEquipment rental depot and workshop
- Test screed moisture with the CM method before coveringScreed
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
Where it has worked
- Made for this work
Whole-body VR teleoperation to record manipulation data
Brochure lists real-time remote control with Pico or Vision Pro.
Fourier ↗
Specifications
8 catalogue values · 0 verifiedSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
Fourier GR-212-DoF dexterous hand version15 specifications · 5 research gaps · reviewed Per arm 3 kgRuntime 2 hShow all 15 specifications and capabilities
- Height
- Weight
approx.
- Actuators
with 12-DoF dexterous hands
- Degrees of freedom per arm
- Degrees of freedom per hand
enhanced hand; basic hand 6
- Payload per hand
approx.
- Arm reach
1.92 m including dexterous hand
- Walking speed
5 km/h
- Max. torque (hip)
- Battery
approx.
- Runtime
average
- Charging time
- Compute
- Sensors
- Stereo camera, 6-axis IMU, six array-type tactile sensors per handManufacturer sourceFourier ↗ · checked
- Software
- Isaac Lab, ROS, MuJoCo, Fourier SDK; VR teleoperation (Pico, Vision Pro)Reported · sellerigus SE & Co. KG (RBTX) ↗ · checked
Capabilities and equipment
- Legs
- YesField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Unknown
- Outdoor use
- Unknown
- Number of arms
- 2Field-level source not recorded
- Hands or end effectors
- Dexterous handsField-level source not recorded
- Hands included
- YesField-level source not recorded
- Payload on body or base
- Not applicable
- IP rating
- Unknown
- SDK / development interface
- ROS, Fourier SDKField-level source not recorded
Operating conditions and configuration notes
- Payload about 3 kg per hand.
- No outdoor, stair or IP rating claims found.
Still missing for Fourier GR-2
Payload, both arms · IP rating · Stairs · Rough ground · Outdoor use
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- General Humanoid Robot Fourier GR-2 product brochure ↗Manufacturer source · checked
- Fourier GR2 humanoid robot, 53 DOF on RBTX ↗Reported · seller · checked
Catalogue specifications
Catalogue values for the base record.
| Size and weight | |||
|---|---|---|---|
| Height | 1.75 m | Reported | robotpriceindex.com |
| Weight | 63 kg | Reported | robotpriceindex.com |
| Payload | |||
| Payload | 3 kg Listed as "Strength" by humanoid.guide; measurement basis not stated. | Reported | humanoid.guide |
| Mobility | |||
| Walking speed | 1.39 m/s | Reported | humanoid.guide |
| Max speed | 1.39 m/s | Reported | robothub.app |
| Power | |||
| Runtime · basis unstated | 2 h | Reported | robothub.app |
| Kinematics | |||
| Degrees of freedom | 53 | Reported | robotpriceindex.com |
| Commercial | |||
| Availability | Prototype | Reported | humanoid.guide |
Not published · 18
Not published anywhere we could find. | |||
Sources disagree
- Weight
- Availability
- Prototypehumanoid.guide
- Preorderhumanoidhub.ai
More detail
Parts, equipment and evidence profileShowHide
Built-in parts
nothing publishedNot published: Hands, Compute, LiDAR, Cameras, Equipment options.
Robot evidence profile
2 of 10 axes with data · tasks UnknownProfile scope: Catalogue model. The chart uses this catalogue record. Configuration-specific findings are listed separately below.
Chart gaps mean evidence is missing. Scores describe the published data against fixed thresholds; they do not predict task success.
Carryunconfirmedworking payload not confirmed; preferred source gives only a peak or unqualified load1 recorded field · 1 follow-up
Rated payload against 5, 10, 20, 40 and 80 kg.
Payload: 3 kg
Listed as "Strength" by humanoid.guide; measurement basis not stated.
Still needed
- Rated working load, arm pose and whether the figure is per arm or combined
Ask before use: What load can this exact configuration sustain while doing the intended task?
Reachunconfirmedworking reach not published; body height does not establish tool or handling reach0 recorded fields · 1 follow-up
Work height against 1.0, 1.5, 2.0 and 2.5 m; unknown when working reach is not published.
No supporting catalogue specification is recorded for this axis.
Still needed
- Vertical working reach from the floor, including the end effector
Ask before use: What usable tool height and work envelope are supported by the fitted arm and base?
Stairs & slopeunconfirmedstair capability not published0 recorded fields · 3 follow-ups
Stair capability, and slope against 10, 20, 30 and 45°.
No supporting catalogue specification is recorded for this axis.
Still needed
- Explicit stair-climbing capability
- Maximum step height and test conditions
- Maximum slope and test surface
Ask before use: Which stair geometry, surface and carried load were tested?
Terrainunconfirmedgravel capability needs configuration-specific evidence0 recorded fields · 2 follow-ups
Configuration-specific evidence for gravel and rubble.
No supporting catalogue specification is recorded for this axis.
Still needed
- Named terrain and configuration-specific test evidence
- Reviewed evidence for gravel and rubble separately
Ask before use: Is gravel or rubble explicitly supported for this configuration? General uneven-ground claims do not establish both.
WeatherunconfirmedIP rating not published0 recorded fields · 3 follow-ups
Heavy dust, damp and rain (IP code), outdoor rating, and −10…35 °C / −20…45 °C.
No supporting catalogue specification is recorded for this axis.
Still needed
- Whole-robot IP rating
- Explicit outdoor-use permission or restriction
- Complete operating temperature range
Ask before use: Do weather ratings apply to the whole robot, including its hands, sensors and battery?
Enduranceunconfirmed2 h (basis unstated) published; loaded work runtime not confirmed1 recorded field · 1 follow-up
Published loaded runtime against 2, 4 and 8 h shifts; nominal/idle figures remain unconfirmed.
Runtime · basis unstated: 2 h
Still needed
- Loaded working runtime with workload stated
Ask before use: How long does it operate with the intended payload and duty cycle, including recharge or battery changes?
Autonomyunconfirmedlevel of autonomy not assessed0 recorded fields · 1 follow-up
Supervised, then fully autonomous operation.
No supporting catalogue specification is recorded for this axis.
Still needed
- Operator role and supported autonomous workflow
Ask before use: Which tasks run without teleoperation, and when must a person intervene?
Handling evidence0/6 supported0 supported; 0 reported only; 6 unconfirmed. Counts describe evidence, not task success.0 recorded fields · 1 follow-up
Supported, reported and unconfirmed handling tasks. Incomplete evidence leaves a chart gap, not a success score.
No supporting catalogue specification is recorded for this axis.
Still needed
- Evidence for the required handling task and fitted end effector
Ask before use: Which grasp, tool and handling tasks have been shown with this exact end effector?
Evidence23/1008 populated fields, 0 manufacturer-sourced0 recorded fields · 0 follow-ups
How much of the record is published and maker-verified.
0 manufacturer-sourced · 0 assessed · 8 reported · 0 with confidence unconfirmed. 3 distinct source links.
Ask before use: Which claims have primary sources, and which still need manufacturer confirmation or a task trial?
A named task is a sourced capability claim. A task not listed remains unconfirmed.
No field-level task evidence is recorded. Task, configuration, source and operating conditions are needed.
Transport
- Carry materialnot assessed
- Fetch and delivernot assessed
- Pick from shelvesnot assessed
- Hand over toolsnot assessed
Inspection & capture
- Site inspectionnot assessed
- 360° progress capturenot assessed
- LiDAR scanningnot assessed
- Patrol / monitoringnot assessed
Manipulation & tools
- Teleoperated handlingnot assessed
- Drillingnot assessed
- Screwingnot assessed
- Sorting materialnot assessed
- Kittingnot assessed
- Machine tendingnot assessed
- Palletisingnot assessed
Navigation
- Navigate indoors alonenot assessed
- Navigate outdoors alonenot assessed
- Climb stairsnot assessed
Site work
- Layout markingnot assessed
- Sweepingnot assessed
- Surface finishingnot assessed
Evidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
Fourier GR-21 published claim · 5 missing capability fields
Configuration: 12-DoF dexterous hand version
- Published claim
Whole-body VR teleoperation to record manipulation data
Location not recorded · Event date not recorded
Brochure lists real-time remote control with Pico or Vision Pro.
Fourier ↗ · Manufacturer source · checked
What is still missing
Payload, both arms · IP rating · Stairs · Rough ground · Outdoor use
- Is the RBTX price for the standard CPU or the 275 TOPS compute option?
Unweighted thresholds use the matcher's rules. Handling shows evidence coverage. Source labels describe provenance and do not certify performance.
Sources
7 pages- General Humanoid Robot Fourier GR-2 product brochure ↗Fourier · manufacturer · checked 2026-10-02
- Fourier GR2 humanoid robot, 53 DOF on RBTX ↗igus SE & Co. KG (RBTX) · seller · checked 2026-11-06
- About Fourier (company timeline) ↗Fourier · manufacturer · checked 2026-11-06
- https://humanoid.guide/product/gr-2/database · 10 values · seen 12 Sept 2026
- https://robotpriceindex.com/robots/fourier-gr-2database · 7 values · seen 12 Sept 2026
- https://www.humanoidhub.ai/robots/gr-2-humanoiddatabase · 3 values · seen 08 Sept 2026
- https://www.robothub.app/en/robots/fourier-gr-2database · 5 values · seen 12 Sept 2026
- Specification data cross-checked against the Humanoid Guide database (humanoid.guide).
- Price ranges cross-checked against Robot Price Index (robotpriceindex.com).
- Sensor and compute details cross-checked against HumanoidHub (humanoidhub.ai).
- Specification data cross-checked against RobotHub (robothub.app).