Buy in Germany
checked 2026-11-18Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
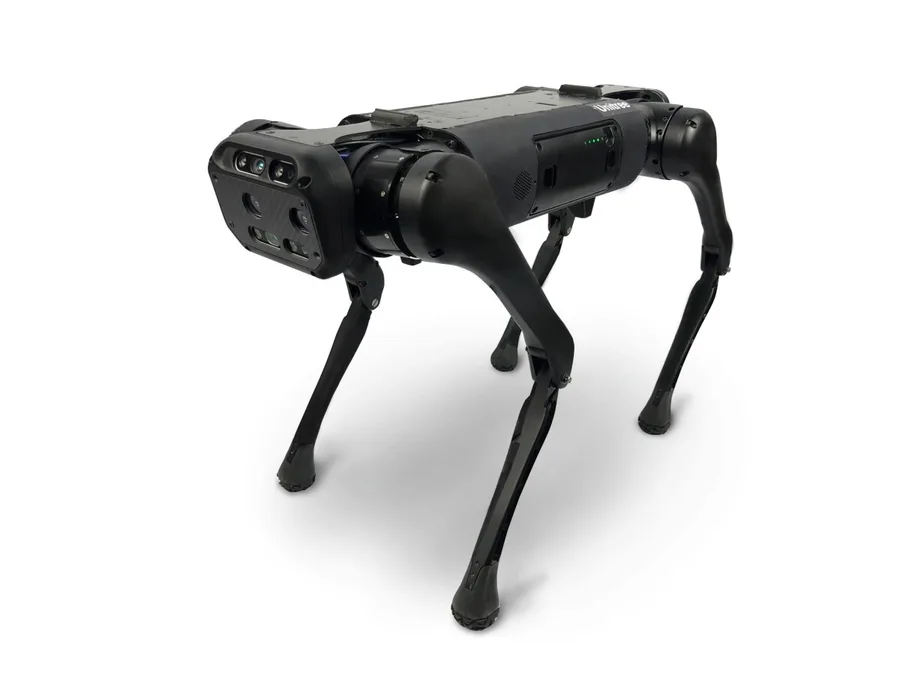
QUADRUPED Robotics (Bergheim, Germany) lists the QUADRUPED Aliengo at 40,235 € excl. VAT with an add-to-cart button; made to order, about 21 days after the order. MYBOTSHOP lists it with price on request. Lead time: Made to order: "Ab Bestellung lieferbar in 21 Tagen"; shown delivery time 23 - 27 working days (quadruped.de).
QUADRUPED Robotics (quadruped.de) DE · reseller · €40,235 net
MYBOTSHOP GmbH DE · reseller
Checked 2026-11-18. Maker’s page ↗
Key facts
All specifications- Moves on
Legs
- Height
- Not published
- Weight
- Arms
None
- Hands
No hands
- Payload per arm
Not applicable
- Carry on body
- Runtime
- Max speed
- Stairs
- Outdoors
- IP rating
Jobs
No job on the map fits this robot yet.
Where it has worked
No real-world work recorded yet.
Specifications
11 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
Unitree Aliengo11 specifications · 0 research gaps · reviewed Body / base payload 13 kgRuntime 2.5 hIP rating IP54Show all 11 specifications and capabilities
- Weight without battery
plus or minus 1 kg
Exact source text
Quote context: plus or minus 1 kg
Weight (without battery)21.5kg ±1kg
- Load
maker figure; the German seller states 10 kg load capacity
Exact source text
Quote context: maker spec table
Load13kg
- Endurance
2.5 to 4.6 h
Exact source text
Quote context: 2.5 to 4.6 h
Endurance2.5-4.6h
- Maximum walking speed
more than 1.5 m/s
Exact source text
Quote context: more than 1.5 m/s
Maximum Walking Speed>1.5m/s
- Climbing angle
up to; the seller states 25 to 30 deg
Exact source text
Quote context: up to; the seller states 25 to 30 deg
Climbing Angle≤25°
- Size standing (L x W x H)
folded 600 x 310 x 150 mm
Exact source text
Quote context: folded 600 x 310 x 150 mm
Length*Width*Height(stand)0.65*0.31*0.6m
- Battery capacity
Exact source text
Battery Capacity12600mAh
- Protection class
seller figure
Exact source text
Quote context: German seller spec table
IP class: IP54
- Sensing
- 2 depth cameras and 1 visual odometry camera; single or multi-line lidar optionalManufacturer sourceUnitree Robotics ↗ · checked
Exact source text
Sensing FunctionDepth Camera (2), Visual Odometer Camera (1)Lidar: Single or Multi-line (optional)
- External interfaces
- Ethernet x2, USB 3.0 x2, USB 2.0 x1, RS485 x1; power out 5 V, 12 V, 19 V and battery voltageManufacturer sourceUnitree Robotics ↗ · checked
Exact source text
External interfaces include: Ethernet port x2, USB 3.0x2, USB 2.0x1, 485 port x1.
- Software interface
- High-level and low-level control interfaces, C/C++ and ROSManufacturer sourceUnitree Robotics ↗ · checked
Exact source text
The software control interface is divided into high-level interface and the underlying interface control interface supports C/C++, ROS, etc.
Capabilities and equipment
- Legs
- YesField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
maker description
Exact source text
Quote context: maker description
it has strong multi-terrain adaptability and can operate stably on rugged gravel roads and grassland roads.
- Stairs
maker sports-function list
Exact source text
Quote context: maker sports-function list
Up and down steps, slopes, stairs
- Outdoor use
maker description of outdoor terrain; IP54 per the German seller
Exact source text
Quote context: maker description of outdoor terrain; IP54 per the German seller
it has strong multi-terrain adaptability and can operate stably on rugged gravel roads and grassland roads.
- Number of arms
- 0Field-level source not recorded
- Hands or end effectors
- NoneField-level source not recorded
- Hands included
- Not applicable
- Payload per arm
- Not applicable
- SDK / development interface
- C/C++ and ROS (high-level and low-level interfaces)Field-level source not recorded
Operating conditions and configuration notes
- A research platform from Unitree's older generation; the newer B2 and A2 are separate records.
- Maker says users can mount their own modules such as cameras, lidar, robotic arms or GPS; none is included.
- Load is 13 kg in Unitree's table and 10 kg in the German seller's table.
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- Unitree Aliengo ↗Manufacturer source · checked
- QUADRUPED Aliengo ↗Reported · seller · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
Unitree AliengoNo task evidence recorded · 0 missing capability fields
No task claim, demonstration, pilot or deployment has been recorded for this configuration.
What is still missing
All tracked capability fields have values. Conditions and task suitability still need checking.
- Launch year not stated on the pages read.
- Whether the seller's price includes the developer version with onboard PC and lidar.
Sources
3 pages- Unitree Aliengo ↗Unitree Robotics · manufacturer · checked 2026-11-18
- QUADRUPED Aliengo ↗QUADRUPED Robotics · seller · checked 2026-11-18
- Unitree Aliengo ↗MYBOTSHOP GmbH · seller · checked 2026-11-18