Buy in Germany
checked 2026-11-18Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
Tokyo Robotics lists the current Torobo as 'Under Development' and takes enquiries by e-mail (info@robotics.tokyo). No German or EU seller or price found.
Checked 2026-11-18. Maker’s page ↗
Key facts
All specifications- Moves on
Wheels
- Height
- Weight
approx. 120 kg
Maker · robotics.tokyo ↗- Arms
2
- Hands
Hands sold separately, not included
- Payload per arm
- Carry on body
- Not published
- Runtime
- Max speed
- Not published
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Needs add-ons or a trial 17
- Check components before assembly handoffFactory parts-preparation trial
- Deliver prepared assembly kits to the lineFactory assembly-line handoff
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Develop force-controlled humanoid handlingWhole-body manipulation research laboratory
- Fetch tools, consumables and kit boxes to the linePrefab timber house factory
Show 12 more
- Kit fittings and hardware for element assemblyPrefab timber house factory
- Load sheet-metal parts into welding fixturesAutomotive body shop
- Move totes between shelving, conveyor and packingMaterial yard and warehouse
- Pick automotive components from flow racksAutomotive parts-sorting station
- Record humanoid manipulation demonstrationsHumanoid learning and teleoperation laboratory
- Research picking objects from floor levelControlled laboratory floor and tabletop
- Restock fastener magazines, clear packaging, tidy workstationsPrefab timber house factory
- Return empty totes after pickingWarehouse empty-container return
- Sequence automotive parts into delivery trolleysAutomotive assembly logistics
- Study fingertip contact during humanoid graspsDexterous manipulation research cell
- Test learned manipulation policies on a physical humanoidRobot learning evaluation cell
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
Where it has worked
- Shown in a demo
Lab demos with impedance control: hammering a nail, sawing wood, box transport by teleoperation
Demo videos listed on the maker site; the maker says some videos show the older Torobo.
Tokyo Robotics ↗
Specifications
6 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
Tokyo Robotics Torobo6 specifications · 5 research gaps · reviewed Per arm 7 kgRuntime up to approx. 3 hShow all 6 specifications and capabilities
- Height
cart width 590 mm
Exact source text
Quote context: cart width 590 mm
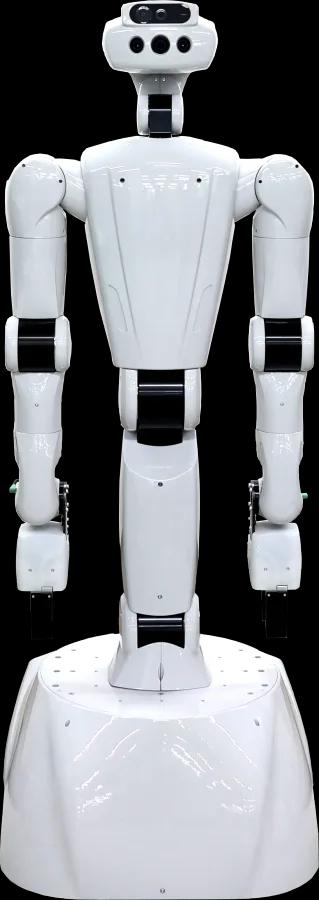
With a height of 1615 mm and a cart width of 590 mm, the size of the robot is close to that of a human.
- Weight
Exact source text
Weight approx. 120 kg
- Payload per arm
worst-case holding posture
Exact source text
Quote context: worst-case holding posture
The payload of one arm is 7 kg at the worst-case holding posture
- Joint configuration
- 7-axis dual arms, 3-axis waist, 3-axis neck, 4-axis omnidirectional baseManufacturer sourceTokyo Robotics ↗ · checked
Exact source text
The joint configuration of 7-axis dual arms, 3-axis waist (pitch, pitch, yaw), 3-axis neck (yaw, pitch, roll), and 4-axis undercarriage (omni-directional mobile base)
- Battery operation time
built-in battery; can run while charging
Exact source text
Quote context: built-in battery; can run while charging
Up to approx. 3 hours
- Software
Exact source text
Since it is ROS-compatible, the robot in Gazebo (a simulator for ROS) and the actual robot can be operated using the same program.
Capabilities and equipment
- Legs
- NoField-level source not recorded
- Wheels
- YesField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Not applicable
- Outdoor use
- Unknown
- Number of arms
- 2Field-level source not recorded
- Hands or end effectors
- OptionalField-level source not recorded
- Hands included
- NoField-level source not recorded
- Payload on body or base
- Unknown
- Runtime
- 3 hField-level source not recorded
- IP rating
- Unknown
- SDK / development interface
- ROS (MoveIt!, Gazebo); simulation models for MuJoCo and Isaac SimField-level source not recorded
Operating conditions and configuration notes
- Head, end effector (hand or in-house gripper) and second PC are options.
- Torque sensors in all arm and waist joints allow impedance control and safe contact stops.
- Tokyo Robotics also shows a bipedal Torobo humanoid prototype in its videos; this record covers the wheeled Torobo.
Still missing for Tokyo Robotics Torobo
Payload, both arms · Payload · IP rating · Rough ground · Outdoor use
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- Torobo ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
Tokyo Robotics Torobo1 demonstration · 5 missing capability fields
- Demonstration
Lab demos with impedance control: hammering a nail, sawing wood, box transport by teleoperation
Location not recorded · Event date not recorded
Demo videos listed on the maker site; the maker says some videos show the older Torobo.
Tokyo Robotics ↗ · Manufacturer source · checked
What is still missing
Payload, both arms · Payload · IP rating · Rough ground · Outdoor use
- Price, release date of the current version and export terms are not published.
- Earlier Torobo versions were supplied to research labs; whether the current one is sold outside Japan is unknown.
Sources
2 pages- Torobo ↗Tokyo Robotics · manufacturer · checked 2026-11-18
- Tokyo Robotics home page ↗Tokyo Robotics · manufacturer · checked 2026-11-18