Buy in Germany
checked 2026-10-05Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
Not sold: Shimizu developed Robo-Welder (with Osaka University) for its own steel-frame projects in Japan and plans to reuse each robot across its sites; no sale, rental or licence offer found.
Checked 2026-10-05. Maker’s page ↗
Key facts
All specifications- Moves on
Wheels
- Height
- Not published
- Weight
- Arms
1
- Hands
Process tool
- Payload per arm
- Carry on body
- Not published
- Runtime
- Not published
- Max speed
- Not published
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Specs fit 2
- Fit and tack-weld end plates, cleats and stiffeners to beamsSteel fabrication shop
- Weld shear studs onto steel beams on siteSteelwork
Where it has worked
- Shown in a demo
Welded steel column joints with grooves of varying shape during trials · Robot laboratory, Shimizu Institute of Technology, Etchujima, Tokyo, Japan · 2018-04
Shimizu Corporation ↗ - In daily use
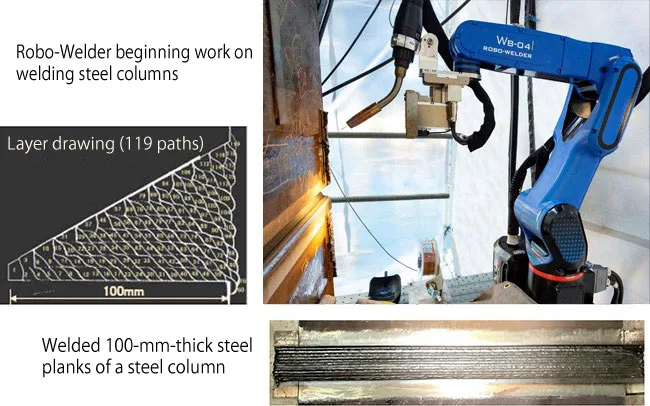
Welded the 100 mm thick plates of the steel columns on the underground floors in 5 man-days per column instead of 8 for master welders; 14 robots planned for the above-ground floors to weld about 15% of around 1,800 km of welds · Toranomon-Azabudai Project, A district (64-storey tower), Minato-ku, Tokyo, Japan; Shimizu as contractor · 2021-02
Shimizu Corporation ↗
Specifications
10 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
Shimizu Robo-Welder10 specifications · 6 research gaps · reviewed Per arm 10 kgShow all 10 specifications and capabilities
- Length x width x height
2018 spec
- Weight
2018 spec
- Arm axes
one arm per robot
- Arm payload
maximum transport capacity of the arm (2018 spec)
- Arm reach
maximum, 2018 spec table; a Shimizu diagram on the topic page shows 901 mm
- Repeat accuracy
2018 spec
- Welding method
2018 spec
- Welding wire diameter
approximately (2021 release)
- Groove sensor
- blue semiconductor laser, 405 nm, measuring range 200 mm ±48 mmManufacturer sourceShimizu Corporation ↗ · checked
2018 spec
- Thickest plate welded on site
steel column plates at Toranomon-Azabudai, 2021
Capabilities and equipment
- Legs
- NoField-level source not recorded
- Wheels
- YesField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Not applicable
- Outdoor use
- Unknown
- Number of arms
- 1Field-level source not recorded
- Hands or end effectors
- ToolField-level source not recorded
- Hands included
- YesField-level source not recorded
- Payload on body or base
- Unknown
- Runtime
- Unknown
- IP rating
- Unknown
- SDK / development interface
- Unknown
Operating conditions and configuration notes
- Sits on a dedicated wheeled carriage that is guided to the column; from there it welds automatically without a worker.
- One six-axis arm per robot (the English 2021 release says "six arms", the Japanese original says a six-axis arm); two robots usually weld one column from opposite sides.
- Plans each weld from the laser-measured groove shape with a simulator developed with Osaka University.
- Specifications are from 2018; the robot shown on site in 2021 looks different (blue arm instead of the orange arm in the 2018 photos), so values may have changed.
Still missing for Shimizu Robo-Welder
Payload · Runtime · IP rating · Rough ground · Outdoor use · SDK / development interface
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- Shimizu begins collaborating people and autonomous robots at Toranomon-Azabudai Project (February 2021) ↗Manufacturer source · checked
- Robots under autonomous control at robot lab (April 2018, with specifications) ↗Manufacturer source · checked
- The Shimizu Smart Site autonomous robots can transform a job site! (April 2018) ↗Manufacturer source · checked
- Shimz Smart Site next-generation production system (July 2017, Japanese) ↗Manufacturer source · checked
- Toranomon-Azabudai robot release (February 2021, Japanese original) ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
Shimizu Robo-Welder1 demonstration · 1 deployment · 5 missing capability fields
- Demonstration
Welded steel column joints with grooves of varying shape during trials
Robot laboratory, Shimizu Institute of Technology, Etchujima, Tokyo, Japan · 2018-04
Shimizu Corporation ↗ · Manufacturer source · checked
- Deployment
Welded the 100 mm thick plates of the steel columns on the underground floors in 5 man-days per column instead of 8 for master welders; 14 robots planned for the above-ground floors to weld about 15% of around 1,800 km of welds
Toranomon-Azabudai Project, A district (64-storey tower), Minato-ku, Tokyo, Japan; Shimizu as contractor · 2021-02
Shimizu Corporation ↗ · Manufacturer source · checked
What is still missing
Payload · Runtime · IP rating · Rough ground · Outdoor use
- Is Robo-Welder still in use on Shimizu sites after Toranomon-Azabudai, and how many robots exist?
- Current specifications: the 2018 table and a Shimizu diagram disagree on arm reach (1,101 vs 901 mm) and arm weight (54 vs 52 kg).
Sources
5 pages- Shimizu begins collaborating people and autonomous robots at Toranomon-Azabudai Project (February 2021) ↗Shimizu Corporation · manufacturer · checked 2026-10-05
- Robots under autonomous control at robot lab (April 2018, with specifications) ↗Shimizu Corporation · manufacturer · checked 2026-10-05
- The Shimizu Smart Site autonomous robots can transform a job site! (April 2018) ↗Shimizu Corporation · manufacturer · checked 2026-10-05
- Shimz Smart Site next-generation production system (July 2017, Japanese) ↗Shimizu Corporation · manufacturer · checked 2026-10-05
- Toranomon-Azabudai robot release (February 2021, Japanese original) ↗Shimizu Corporation · manufacturer · checked 2026-10-05