Buy in Germany
checked 2026-11-18Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
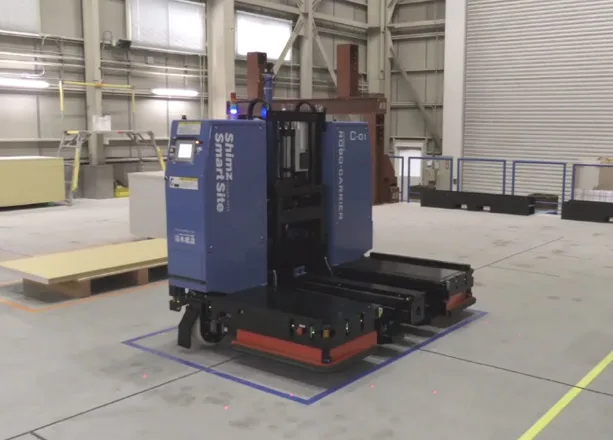
Developed by Shimizu for its own construction sites in Japan; no sale, rental or German route found.
Checked 2026-11-18. Maker’s page ↗
Key facts
All specifications- Moves on
Wheels
- Height
- Not published
- Weight
- Not published
- Arms
None
- Hands
No hands
- Payload per arm
Not applicable
- Carry on body
990 kg
- Runtime
- Not published
- Max speed
- Not published
- Stairs
No
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Shown in a demo 1
- Bring fittings, fixings and tools to the installersShown in a demo · Shimizu Institute of Technology robot laboratory, Etchujima, Tokyo, Japan
Specs fit 1
- Distribute bagged plaster and mortar to the work areasSite setup and logistics
Where it has worked
- Shown in a demo
Lifted a pallet of plasterboard (about 1 t), carried it into a temporary elevator and on to a set location · Shimizu Institute of Technology robot laboratory, Etchujima, Tokyo, Japan · 2018-04
Shimizu Corporation ↗ - Made for this work
Planned to carry palletised materials from the ground floor via the freight elevator to the work spots on each floor · Toranomon-Azabudai Project (A district, 64 floors), Minato-ku, Tokyo, Japan · 2021-02
Shimizu said in February 2021 that Robo-Carrier was scheduled to begin operation there that summer; no later confirmation read.
Shimizu Corporation ↗
Specifications
6 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
Shimizu Robo-Carrier6 specifications · 4 research gaps · reviewed Body / base payload 990 kgShow all 6 specifications and capabilities
- Max. load
Exact source text
990 kg
- Size (L × W × H)
Exact source text
2,000 mm
- Speed
Exact source text
2.4 km/h
- Surmountable height
Exact source text
15 mm
- Navigation
- laser scanners compared with BIM spatial data; reroutes around obstacles; links with the temporary elevatorManufacturer sourceShimizu Corporation ↗ · checked
Exact source text
the Robo-Carrier uses lasers to obtain real-time spatial data which it compares with other spatial data acquired from BIM
- Operation
- operator picks the materials and the destination on a tabletManufacturer sourceShimizu Corporation ↗ · checked
Exact source text
when the operator selects materials to convey and enters their destination in a tablet
Capabilities and equipment
- Legs
- NoField-level source not recorded
- Wheels
- YesField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- NoField-level source not recorded
- Stairs
- NoField-level source not recorded
- Outdoor use
- Unknown
- Number of arms
- 0Field-level source not recorded
- Hands or end effectors
- NoneField-level source not recorded
- Hands included
- Not applicable
- Payload per arm
- Not applicable
- Payload on body or base
- 990 kgField-level source not recorded
- Runtime
- Unknown
- IP rating
- Unknown
- SDK / development interface
- Unknown
Operating conditions and configuration notes
- Lifts pallets with a scissor fork; the lab test carried a pallet of plasterboard weighing about one tonne into a temporary elevator.
- Steps of only 15 mm can be crossed, so it needs finished, level slabs; it moves between floors by riding the elevator, not stairs.
- A collision-prevention feature stops it when a person comes near.
- The spec table gives the weight as '1,160 mm', an obvious unit error, so no weight is recorded.
Still missing for Shimizu Robo-Carrier
Runtime · IP rating · Outdoor use · SDK / development interface
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- Robots under Autonomous Control at Robot Lab (April 2018, with specifications) ↗Manufacturer source · checked
- Shimizu Begins Collaborating People and Autonomous Robots at Construction Site, Toranomon-Azabudai Project (February 2021) ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
Shimizu Robo-Carrier1 published claim · 1 demonstration · 3 missing capability fields
- Demonstration
Lifted a pallet of plasterboard (about 1 t), carried it into a temporary elevator and on to a set location
Shimizu Institute of Technology robot laboratory, Etchujima, Tokyo, Japan · 2018-04
Shimizu Corporation ↗ · Manufacturer source · checked
- Published claim
Planned to carry palletised materials from the ground floor via the freight elevator to the work spots on each floor
Toranomon-Azabudai Project (A district, 64 floors), Minato-ku, Tokyo, Japan · 2021-02
Shimizu said in February 2021 that Robo-Carrier was scheduled to begin operation there that summer; no later confirmation read.
Shimizu Corporation ↗ · Manufacturer source · checked
What is still missing
Runtime · IP rating · Outdoor use
- Did Robo-Carrier go into regular use at Toranomon-Azabudai or other sites after 2021? Only the plan was read.
- A forklift version (Robo-Carrier Fork) was reported in 2022 with rental or sale in view; no source for it was read.
- Weight and runtime: not stated (the weight cell on the spec table is a unit error).
Sources
3 pages- Robots under Autonomous Control at Robot Lab (April 2018, with specifications) ↗Shimizu Corporation · manufacturer · checked 2026-11-18
- Shimizu Begins Collaborating People and Autonomous Robots at Construction Site, Toranomon-Azabudai Project (February 2021) ↗Shimizu Corporation · manufacturer · checked 2026-11-18
- The Shimizu Smart Site autonomous robots can transform a job site! ↗Shimizu Corporation · manufacturer · checked 2026-11-18