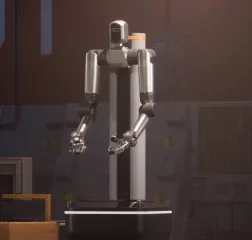
Buy in Germany
checked 2026-11-18Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
Perceptyne (Hyderabad, India) shows a pre-order button and a spec-sheet request form; no German or EU seller, distributor or price found.
Checked 2026-11-18. Maker’s page ↗
Key facts
All specifications- Moves on
Wheels
- Height
- Not published
- Weight
120 kg
Maker · perceptyne.com ↗- Arms
2
- Hands
Grippers
- Payload per arm
- Carry on body
- Not published
- Runtime
- Max speed
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Specs fit 11
- Check components before assembly handoffFactory parts-preparation trial
- Deliver prepared assembly kits to the lineFactory assembly-line handoff
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Develop force-controlled humanoid handlingWhole-body manipulation research laboratory
- Kit fittings and hardware for element assemblyPrefab timber house factory
Show 6 more
- Load sheet-metal parts into welding fixturesAutomotive body shop
- Pick automotive components from flow racksAutomotive parts-sorting station
- Research picking objects from floor levelControlled laboratory floor and tabletop
- Restock fastener magazines, clear packaging, tidy workstationsPrefab timber house factory
- Return empty totes after pickingWarehouse empty-container return
- Sequence automotive parts into delivery trolleysAutomotive assembly logistics
Needs add-ons or a trial 11
- Insert insulation batts into the frame baysPrefab timber house factory
- Lay carpet tiles on tackifierFloor coverings and parquet
- Lay click parquet planks floating on an underlayFloor coverings and parquet
- Lay click vinyl planks floatingFloor coverings and parquet
- Lay drainage pipes inside the building to fallsWater, gas and drainage installations
Show 6 more
- Lay impact-sound insulation and edge strips under a floating screedScreed
- Place electrical boxes, conduit and small inserts before concretingPrecast concrete plant
- Recover beverage cartons from paper linesMaterial recovery facility
- Recover light recyclables from residue beltsMaterial recovery facility
- Set corner beads before plasteringPlaster and stucco
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
Where it has worked
- Made for this work
Pick, place, bolt, inspect, test, assemble and insert in factory workflows
Maker's application list; press says its solutions serve EMS and automotive clients, without naming a PR-OMNI deployment.
Perceptyne ↗
Specifications
11 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
Perceptyne PR-OMNI11 specifications · 6 research gaps · reviewed Per arm 5 kgRuntime 6 hShow all 11 specifications and capabilities
- Height
Exact source text
Height5’2”
- Weight
Exact source text
Weight120 kg
- DOF per arm
dual arms
Exact source text
Quote context: dual arms
ArmsDual arms, 7 DOF each
- Payload
product page; home page gives 10 kg combined for both arms
Exact source text
Quote context: product page; home page gives 10 kg combined for both arms
Payload - 5kg
- Payload, both arms
combined
Exact source text
Quote context: combined
Payload10 kg combined
- Arm reach
max working reach 2000 mm
Exact source text
Quote context: max working reach 2000 mm
Max working Reach - 2000mmPayload - 5kgBattery - Swappable (1.5 Kwh x2)Arm length - 800mm
- Vertical gantry range
max vertical approach speed 1 m/s
Exact source text
Quote context: max vertical approach speed 1 m/s
Vertical Gantry Range800 mmMax Vertical Approach Speed 1 m/s
- Max speed
4-wheel holonomic drive
Exact source text
Quote context: 4-wheel holonomic drive
Drive Type4 Wheel holonomic driveMax Speed2 m/s
- Runtime
3 kWh, two swappable 1.5 kWh packs
Exact source text
Quote context: 3 kWh, two swappable 1.5 kWh packs
Runtime6 hoursBattery Capacity3 kWh (2 × 1.5 kWh, swappable)
- Compute
Exact source text
ComputeNvidia Jetson Orin + Intel NUC 5th Gen
- Sensing
- force-torque sensing at every joint, tactile end effectors, 3 RGBD cameras, dual LiDAR SLAMManufacturer sourcePerceptyne ↗ · checked
indoor navigation
Exact source text
Quote context: indoor navigation
Joint SensorsForce-torque sensing at every jointEnd-Effector SensorsTactile sensingVision3 RGBD cameras (2 wrists + 1 head)
Capabilities and equipment
- Legs
- NoField-level source not recorded
- Wheels
- YesField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Not applicable
- Outdoor use
- Unknown
- Number of arms
- 2Field-level source not recorded
- Hands or end effectors
- GripperField-level source not recorded
- Hands included
- Unknown
- Payload on body or base
- Unknown
- IP rating
- Unknown
- SDK / development interface
- Unknown
Operating conditions and configuration notes
- Navigation is described as indoor SLAM with dual LiDARs.
- End-effector type is not named; the end effectors have tactile sensing.
- VR teleoperation is built in for data collection.
- A stationary sister model, PR-DUO, has the same arms without the mobile base and is not covered here.
Still missing for Perceptyne PR-OMNI
Payload · IP rating · Rough ground · Outdoor use · Hands included · SDK / development interface
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- PR-OMNI ↗Manufacturer source · checked
- Perceptyne home page ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
Perceptyne PR-OMNI1 published claim · 5 missing capability fields
- Published claim
Pick, place, bolt, inspect, test, assemble and insert in factory workflows
Location not recorded · Event date not recorded
Maker's application list; press says its solutions serve EMS and automotive clients, without naming a PR-OMNI deployment.
Perceptyne ↗ · Manufacturer source · checked
What is still missing
Payload · IP rating · Rough ground · Outdoor use · Hands included
- Whether the 5 kg payload is per arm (the home page gives 10 kg combined).
- Price, delivery date and any export or EU distribution are not published.
- Relation to the older PR-34D model named in press is not explained on the maker site.
Sources
3 pages- PR-OMNI ↗Perceptyne · manufacturer · checked 2026-11-18
- Perceptyne home page ↗Perceptyne · manufacturer · checked 2026-11-18
- Perceptyne Robots: Engineering India's robotic future ↗The New Indian Express · press · checked 2026-11-18