Buy in Germany
checked 2026-11-06Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
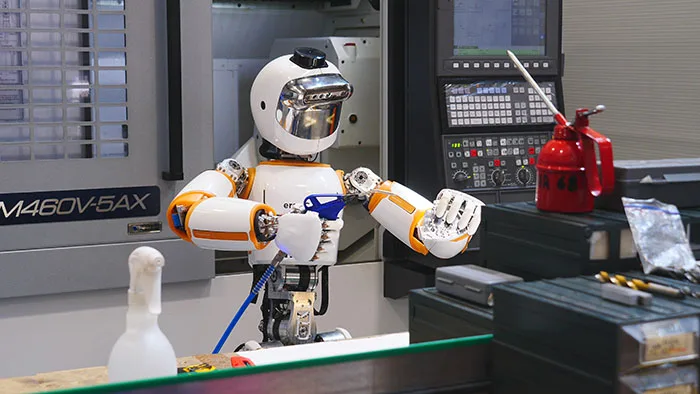
Research robot of the ergoCub project (IIT with INAIL, Italy); no sales offer, price or customer deliveries found.
Checked 2026-11-06. Maker’s page ↗
Key facts
All specifications- Moves on
Legs
- Height
1.5 m
Maker · ergocub.eu ↗- Weight
55.7 kg
Maker · ergocub.eu ↗- Arms
2
- Hands
Multi-finger hands
- Payload per arm
- Carry on body
- Not published
- Runtime
- Not published
- Max speed
- Not published
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Shown in a demo 1
- Develop force-controlled humanoid handlingShown in a demo · IIT, Genoa, Italy
Needs add-ons or a trial 11
- Check components before assembly handoffFactory parts-preparation trial
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Kit fittings and hardware for element assemblyPrefab timber house factory
- Pick automotive components from flow racksAutomotive parts-sorting station
- Record humanoid manipulation demonstrationsHumanoid learning and teleoperation laboratory
Show 6 more
- Research picking objects from floor levelControlled laboratory floor and tabletop
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
- Restock fastener magazines, clear packaging, tidy workstationsPrefab timber house factory
- Sequence automotive parts into delivery trolleysAutomotive assembly logistics
- Study fingertip contact during humanoid graspsDexterous manipulation research cell
- Test learned manipulation policies on a physical humanoidRobot learning evaluation cell
Where it has worked
- Shown in a demo
Collaborative lifting with a sensorised worker; load transport and navigation in a simulated warehouse · IIT, Genoa, Italy
ergoCub project (IIT, INAIL) ↗
Specifications
3 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
IIT ergoCub3 specifications · 8 research gaps · reviewed Show all 3 specifications and capabilities
- Height
- Weight
- Load-bearing
Approximately, as stated by the project
Capabilities and equipment
- Legs
- YesField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Unknown
- Outdoor use
- Unknown
- Number of arms
- 2Field-level source not recorded
- Hands or end effectors
- Dexterous handsField-level source not recorded
- Hands included
- YesField-level source not recorded
- Payload per arm
- Unknown
- Payload on body or base
- Not applicable
- Runtime
- Unknown
- IP rating
- Unknown
- SDK / development interface
- Unknown
Operating conditions and configuration notes
- Research prototype; walks at about human speed and carries several kilograms while walking (project page).
Still missing for IIT ergoCub
Payload per arm · Payload, both arms · Runtime · IP rating · Stairs · Rough ground · Outdoor use · SDK / development interface
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- ergoCub robot ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
IIT ergoCub1 demonstration · 7 missing capability fields
- Demonstration
Collaborative lifting with a sensorised worker; load transport and navigation in a simulated warehouse
IIT, Genoa, Italy · Event date not recorded
ergoCub project (IIT, INAIL) ↗ · Manufacturer source · checked
What is still missing
Payload per arm · Payload, both arms · Runtime · IP rating · Stairs · Rough ground · Outdoor use
Sources
2 pages- ergoCub robot ↗ergoCub project (IIT, INAIL) · manufacturer · checked 2026-11-06
- ergoCub project home ↗ergoCub project (IIT, INAIL) · manufacturer · checked 2026-11-06