Buy in Germany
checked 2026-10-02Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
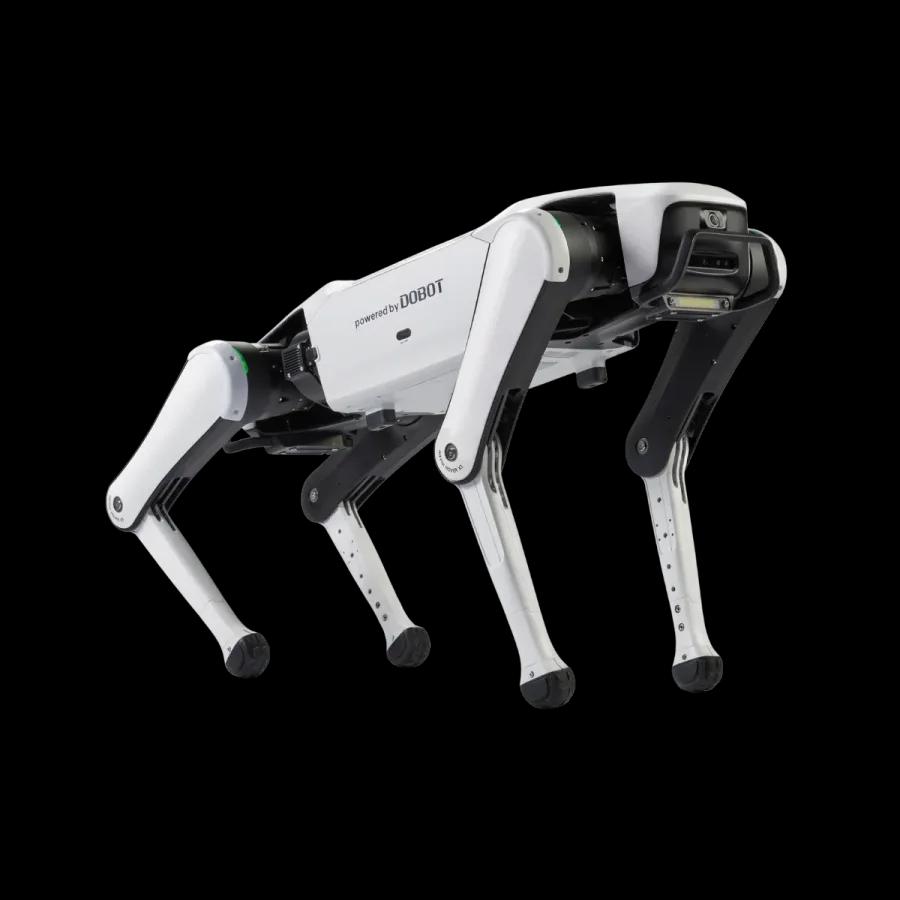
Terra Robotics (Germany) lists Basic EDU EUR 3,999, Smart EDU EUR 4,999 and Max EDU EUR 6,999 (all net) with an order button; on 2026-10-02 only the Max EDU was orderable, Basic and Smart showed as not available.
Terra Robotics (Terra Connect GmbH) DE · reseller · €3,999 net
Product page ↗Contact ↗mail@terra-robotics.de+49 5732 8411620
Checked 2026-10-02. Maker’s page ↗
Key facts
All specifications- Moves on
Legs
- Height
- Not published
- Weight
- Arms
None
- Hands
No hands
- Payload per arm
Not applicable
- Carry on body
3 to 7 kg
Reported · terra-robotics.de ↗- Runtime
3 h
Basic EDU up to 3 h; Smart and Max EDU about 2.5 h; 8000 mAh battery
Reported · terra-robotics.de ↗- Max speed
- Stairs
- Not published
- Outdoors
- IP rating
- Not published
Jobs
Made for this work 1
- Validate mapping and navigation on a legged platformMade for this work
Where it has worked
- Made for this work
Lidar SLAM mapping and autonomous route planning for research (Max EDU)
Seller description; no customer named.
Terra Robotics ↗
Specifications
10 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
DOBOT Rover X1 Explorer EDUBasic EDU / Smart EDU / Max EDU10 specifications · 2 research gaps · reviewed Body / base payload 3-7 kgRuntime 3 hShow all 10 specifications and capabilities
- Net weight
15.5 kg with point feet, 18.5 kg with wheel feet
- Size standing (L x W x H)
wheel legs; 761 x 372 x 428 mm with point legs
- Max. speed
wheel legs; 1.8 m/s with point legs
- Extra payload
- Max. climbing angle
- Runtime
Basic EDU up to 3 h; Smart and Max EDU about 2.5 h; 8000 mAh battery
- Compute
Smart EDU and Max EDU; Basic EDU has the standard platform
- Sensors
- Front and rear cameras; Intel RealSense D435i (Smart, Max); Livox Mid360 lidar SLAM (Max only)Reported · sellerTerra Robotics ↗ · checked
- SDK
- Unified SDK for secondary development, high- and low-level controlReported · sellerTerra Robotics ↗ · checked
same code across Basic, Smart and Max
- Wheel-foot kit
Capabilities and equipment
- Legs
- YesField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
Exact source text
vereint diese Plattform die Schnelligkeit von Radantrieben mit der extremen Geländegängigkeit von Laufrobotern [combines the speed of wheel drives with the extreme off-road capability of legged robots]
- Stairs
- Unknown
- Outdoor use
Exact source text
Der DOBOT Rover X1 kann in geeigneten Outdoor- und Semi-Outdoor-Umgebungen eingesetzt werden, etwa auf Campusflächen, Gehwegen oder leicht unebenem Gelände. [The DOBOT Rover X1 can be used in suitable outdoor and semi-outdoor environments, for example on campus areas, footpaths or slightly uneven ground.]
- Number of arms
- 0Field-level source not recorded
- Hands or end effectors
- NoneField-level source not recorded
- Hands included
- Not applicable
- Payload per arm
- Not applicable
- Payload on body or base
- 3 kgField-level source not recorded
- Runtime
- 2.5 hField-level source not recorded
- IP rating
- Unknown
- SDK / development interface
- Unified SDK (high- and low-level control)Field-level source not recorded
Operating conditions and configuration notes
- Wheel-leg operation needs the wheel-foot kit, which Terra sells as a separate accessory; the seller does not say whether it is included.
- Payload 3 to 7 kg; 3 kg used here as the safe value.
- Runtime about 2.5 h for Smart and Max EDU, up to 3 h for Basic EDU.
- No IP rating stated; an education and research platform, not a site machine.
Still missing for DOBOT Rover X1 Explorer EDU
IP rating · Stairs
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- Dobot Rover X1 Explorer Roboterhund ↗Reported · seller · checked
- Dobot Rover X1 Wheeled-foot Accessory Kit ↗Reported · seller · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
DOBOT Rover X1 Explorer EDU1 published claim · 2 missing capability fields
Configuration: Basic EDU / Smart EDU / Max EDU
- Published claim
Lidar SLAM mapping and autonomous route planning for research (Max EDU)
Location not recorded · Event date not recorded
Seller description; no customer named.
Terra Robotics ↗ · Reported · seller · checked
What is still missing
IP rating · Stairs
- DOBOT does not publish the Explorer EDU versions on its own websites; confirm configuration and SDK with DOBOT or Terra.
- Delivery time for Basic and Smart EDU, which showed as not available.
- CE marking.
- Stair climbing not stated.
Sources
3 pages- Dobot Rover X1 Explorer Roboterhund ↗Terra Robotics · seller · checked 2026-10-02
- Dobot Rover X1 Wheeled-foot Accessory Kit ↗Terra Robotics · seller · checked 2026-10-02
- Rover X1 home robot dog (Chinese product page) ↗DOBOT · manufacturer · checked 2026-10-02